PCB Stator Layer Count: How to Select the Right Structure
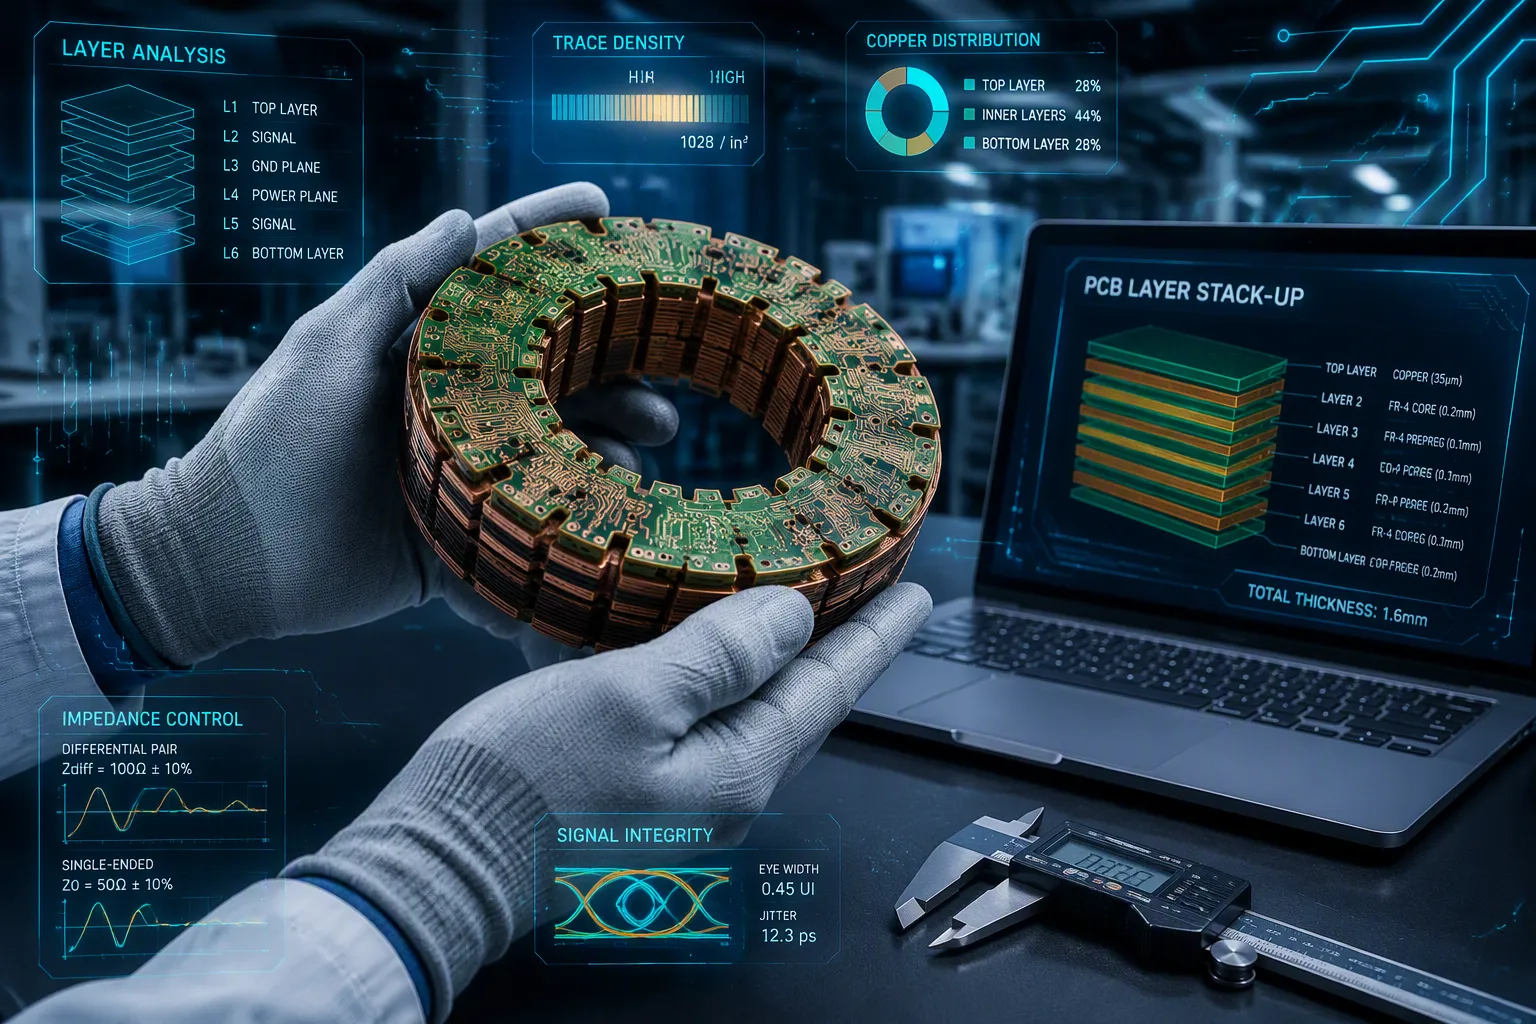
There is no single best pcb stator layer count for every case. The right number balances electrical performance, cost, and what the job needs. Pick a layer count by using models of electromagnetics, heat, and mechanics. A strong pcb stator reduces eddy current losses.
Unlike motors with wire windings, printed circuit board motors put the stator, rotor, and drive circuit all on the substrate. This setup sets the limits for heat and mechanical strength. To get the best from pcb motors, you need to understand these trade-offs. A well-made printed circuit board stator lowers complexity.
You will find simple rules based on frequency, current, pin density, and budget. Find out how many layers you need. The goal is the smallest number that meets your needs without added cost. Pcb motors gain from this focused method. Whether you need a fast pcb motor or a cheap sensor, this plan helps.
Key Takeaways
Pick the lowest number of layers that works for your electrical and heat needs. Try it out first.
Place vias close to the coils and make them wide. This lowers resistance more than adding extra layers.
Adding more layers raises cost and weight without sure performance gains. Heat limits cap the benefits.
Match the layer count to your motor's current, frequency, and layout density. Use simulation to check it.
Build a prototype with the simplest design. Add layers only when tests show they are needed.
How PCB Stator Layer Count Affects Performance
The Performance-Cost Trade-Off
You add copper planes to a pcb stator to raise current capacity. More parallel paths cut total resistance. Lower resistance means less heat from I²R losses. This sounds simple. But each extra layer adds cost and complexity. The substrate gets thicker and heavier. Making it takes more steps and tighter tolerances. You also need more vias to link the layers. Each via adds a bit of resistance on its own. The via aspect ratio gets harder to handle with thicker boards. Drilling deep vias costs more and lowers yield. You must weigh the current gain against these penalties. For pcb motors in weight-sensitive uses, the extra mass counts. The cost does not rise in a straight line. Going from two to four levels may double the cost. Going from four to six can triple it. This jump comes from longer lamination cycles and stricter registration tolerances. A design with two copper levels handles low-current uses well. Four levels fit moderate currents. Past six levels, you get smaller gains per addition. Do not add planes unless the gain clearly beats the added cost.
When More Layers Actually Help
More planes do not always make your pcb motor better. You reach a point of diminishing returns. Thermal limits become the real barrier. The inner copper planes make heat that must escape through the outer surfaces. No number of internal planes changes this basic limit. The surface area and airflow set the most heat that can leave. Once you hit this thermal ceiling, extra levels add nothing. Electromagnetic coupling also causes trouble. Copper levels placed close together can interfere with each other. This interference makes eddy currents and extra losses. Your stator efficiency may fall instead of rise. High-frequency designs face one more problem. The skin effect keeps current in the outer levels. Inner planes carry very little current in that case. Adding internal levels gives almost no gain. You must model the operating conditions with care. Run thermal and electromagnetic simulations before you commit to a design for pcb motors. Build the lowest workable number first. Test it under real load conditions. Measure temperature rise at the expected operating points. Scale up only when measurements show a clear need. This approach saves development time and gives a cleaner design.
Key Factors Behind PCB Stator Design
Frequency, Current, and Thermal Load
Frequency sets the first limit on your design. At low frequencies, current moves evenly through every copper layer. You can use fewer layers and still get good results. As frequency goes up, the skin effect pushes current to the outer surfaces. Inner layers then carry very little current. Adding more internal copper layers gives you almost no gain in that case. You waste material and money on copper that does nothing.
Current demand drives your copper thickness and layer count together. High current needs more copper cross-section to keep resistance low. You can reach that cross-section with thicker copper on fewer layers or thinner copper on more layers. A multi-layer stacked structure often wins when board area is tight. The parallel paths also cut inductance, which helps at higher switching speeds.
Thermal performance ties directly to current. Every amp that flows through resistive copper makes heat. That heat must escape through the pcb substrate and into the air. Internal layers sit far from the surface, so their heat has a long path out. A thinly printed circuit board stator with many buried layers traps heat inside. The thermal resistance rises with each added layer of epoxy-glass laminate. You must model this before you commit to a stack-up. Run a thermal simulation at your worst-case current and ambient temperature. If the predicted rise goes past your insulation rating, add surface area or airflow instead of more layers.
Circuit Complexity and Pin Density
Circuit complexity often forces your hand on layer count. A design where each layer carries only one electrical phase simplifies routing and reduces cross-coupling. Three-phase pcb motors commonly use this approach. You give one layer to each phase, which keeps copper traces from different phases physically apart. That separation cuts parasitic capacitance and eddy current losses.
Pin density matters just as much. Fine-pitch components and dense connector arrays need many escape routes. A high pin count on a small pcb substrate leaves little room for routing on two layers. You then need more layers to break out all the signals. The number of connections between layers grows with pin count, and each via takes space and adds resistance.
Via design deserves more attention than most engineers give it. Via position and diameter affect loss far more than via count alone. A short, wide via near the current path has much lower resistance than a long, narrow one placed far away. Place vias close to the copper foil coils they serve. Size them as large as your design rules allow. This single change often lets you drop a layer without losing performance.
You can connect coils either in series or in parallel to tune resistance and inductance. Series connections raise resistance and suit low-current, high-voltage drives. Parallel connections lower resistance and fit high-current, low-voltage drives. Choose the connection scheme first, then pick the pcb stator layer count that supports it. The goal is always the smallest number of layers that meet your electrical, thermal, and mechanical needs. Extra layers add cost, weight, and via complexity without guaranteed benefit. Build the leanest stack-up your design allows, measure it under real load, and add layers only when the data demands it.
Rules of Thumb for Layer Selection
Quick Estimation by Application Type
You can pick a starting point for your pcb stator layer count with a few simple rules. Match the number to your current level, frequency, and layout density. Then refine the choice with simulation and testing.
Application Profile | Starting Layer Count |
|---|---|
Low current, low frequency | 2 layers |
Moderate current, compact layout | 4 layers |
High density or high frequency | 6 or more layers |
A low-current, low-frequency design works well with two layers. The current spreads evenly through the copper. You get good performance without extra cost. A moderate-current design with a tight layout needs four layers. The extra copper carries more current and the inner planes help with routing. High-density or high-frequency pcb motors need six or more layers. These designs face skin effect losses and complex routing demands.
These numbers give you a baseline. They do not replace simulation. Always model your worst-case thermal and electromagnetic conditions. The table above helps you start the conversation with your fabricator.
High-Density Interconnect and BGA
Ball grid array packages and fine-pitch components change the calculation. A BGA forces you to route many signals from a small area. You cannot escape all those connections on two layers. The copper traces crowd together and create crosstalk. You need more layers to break out the signals and keep them separated.
Fine-pitch routing also demands tighter registration tolerances. Multilayer pcb fabrication becomes harder as pitch shrinks. Each added layer increases the risk of misalignment. You must weigh the routing benefit against the yield loss.
A BGA with a high ball count often needs four to six layers just for escape routing. Add more layers if you also need power planes or ground planes. The substrate thickness grows with each layer. This growth affects the mechanical fit in your motor assembly.
You can reduce the layer count with careful via placement. Use microvias or blind vias to free up routing space. These vias cost more than through-hole vias. But they often save a layer or two. That trade-off usually favors the via investment.
The stator in a compact pcb motor often uses a BGA driver chip. You must route the gate signals and sense lines without noise coupling. More layers give you room to separate noisy and quiet signals. But you pay for that room in cost and weight.
Start with the lowest count your router allows. Check the design rules for your fabricator. Many shops offer standard stack-ups that keep costs low. Use those stack-ups when possible. Add layers only when the routing or thermal data proves you need them.
Cost Optimization and Axial-Flux Motor Examples
Trimming Layers Without Losing Performance
You can often lower cost by taking out layers your design does not really need. Start with the lowest count that works and test it under real load. Many engineers add too many layers because they worry about heat failure. Testing and simulation usually show that fewer layers work just fine.
Focus on via placement before you add copper. A short, wide via near the current path lowers resistance more than an extra layer ever will. You save material cost and make the board thinner at the same time. This approach keeps your stator lean and your budget safe.
Axial-Flux Motor and Robotics Cases
An axial-flux motor design often starts with four layers for moderate current. Engineers build that count first, then test temperature rise at peak load. If the rise stays within limits, they stop there. If not, they add layers only where the data shows a clear need.
A robotics application using an air-core axial-flux permanent-magnet motor chose two layers for a low-current joint. The team measured eddy current losses and found them acceptable. They avoided the cost of a thicker stack-up. Another team building an axial-flux permanent-magnet motor for a compact drive needed six layers. High pin density from the gate driver forced the increase. They used microvias to save space and keep the substrate thin.
For pcb motors in weight-sensitive robots, every layer adds mass. You must balance copper cross-section against payload capacity. A pcb motor with fewer layers often wins when the current demand is modest. Test your pcb coils under worst-case conditions before you commit to a final stack-up. The axial-flux motor in a high-speed application may need more layers for skin effect reasons. Always prototype the lowest count first. Scale up only when measurements demand it.
First, match your pcb stator layer count to current, frequency, and mechanical limits. After that, you work on lowering cost. Via position and diameter cut loss more than just adding layers ever can. Put vias near the coils and make them wide. Build a test version with the lowest workable count for your pcb motor. Add more only when your measurements show you must. This way keeps your stator light and your budget safe. New designs for pcb motors are moving toward denser stack-ups. Fresh axial-flux motor ideas use a thinner substrate and better via structures. These changes will let you fit more power into fewer layers. An axial-flux motor made today may need fewer layers tomorrow.
FAQ
How many layers does a pcb stator need?
The right count depends on your current, frequency, and layout density. Start with two layers for low-current, low-frequency designs. Move to four layers for moderate current and compact routing. Choose six or more layers for high-density or high-frequency work. Always confirm your choice with simulation and real-load testing.
Do more layers always improve pcb motors?
No. Extra layers raise current capacity and cut resistance, but they also add cost, weight, and via complexity. Thermal limits and electromagnetic coupling create diminishing returns. Once you hit the thermal ceiling, more copper planes add nothing. High-frequency designs suffer most because the skin effect keeps current in the outer layers.
Why does via design matter more than layer count?
Via position and diameter affect loss far more than the number of layers. A short, wide via near the current path has much lower resistance than a long, narrow one placed far away. Place vias close to the coils they serve and size them as large as your design rules allow. This often lets you drop a layer without losing performance.
Should I prototype the lowest layer count first?
Yes. Build the leanest stack-up your design allows and test it under worst-case load. Measure temperature rise at your expected operating points. Add layers only when the data shows a clear need. This approach saves development time, keeps pcb motors light, and protects your budget.
See Also
A Guide To Common Stack-Up Designs For HDI Multilayer PCBs
Challenges In Manufacturing And Prototyping Multi-Layer Circuit Boards Explained
Essential Knowledge Needed For Successful PCB Multi-Layer Circuit Board Layout
An In-Depth Look At How Multilayer PCBs Are Manufactured
Understanding The Production Process For Multilayer Rigid-Flex Circuit Boards
